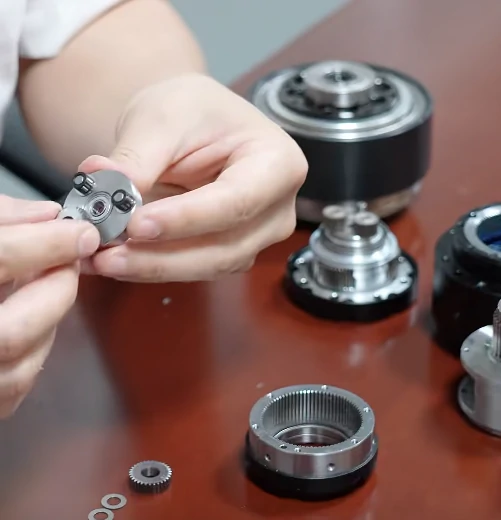
Why Does Humanoid Robot Transmission Require Precision Gear Components? Humanoid robots rely on compact transmission systems to convert motor output into controlled movement across their joints. In applications such as hip and knee drives, shoulder mechanisms, and wrist assemblies, planetary gears for humanoid robots can provide a compact, coaxial transmission arrangement where space and torque requirements […]
 English
 Português do Brasil
 Deutsch (Österreich)
 Deutsch (Schweiz)
 English (UK)
 English (Australia)
 English (New Zealand)
 Deutsch
 Français du Canada
 Français
 Français de Belgique
 Italiano
 English (South Africa)
 Português
 Español
 Español de México
 Español de Perú
 Español de Colombia
 العربية
 日本語
 Русский
 한국어
 Tiếng Việt
 ไทย